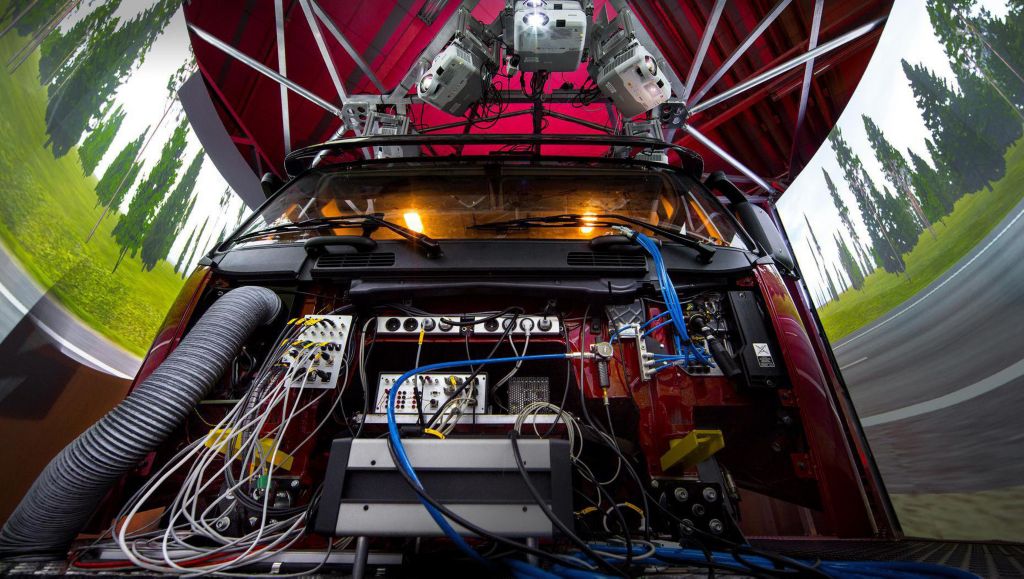
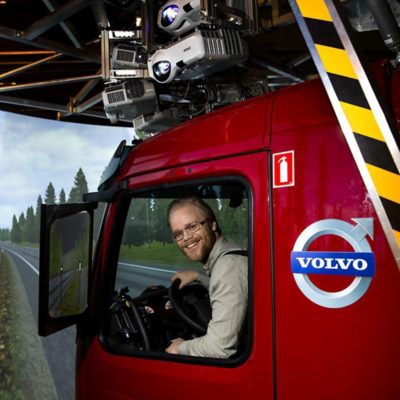
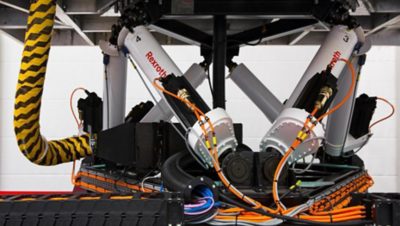
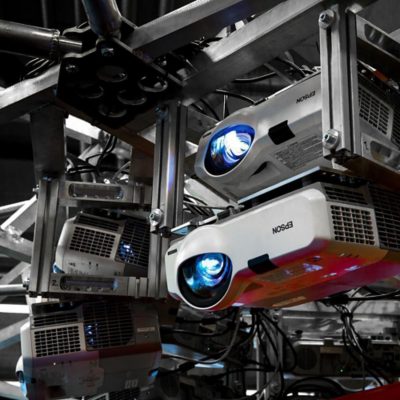
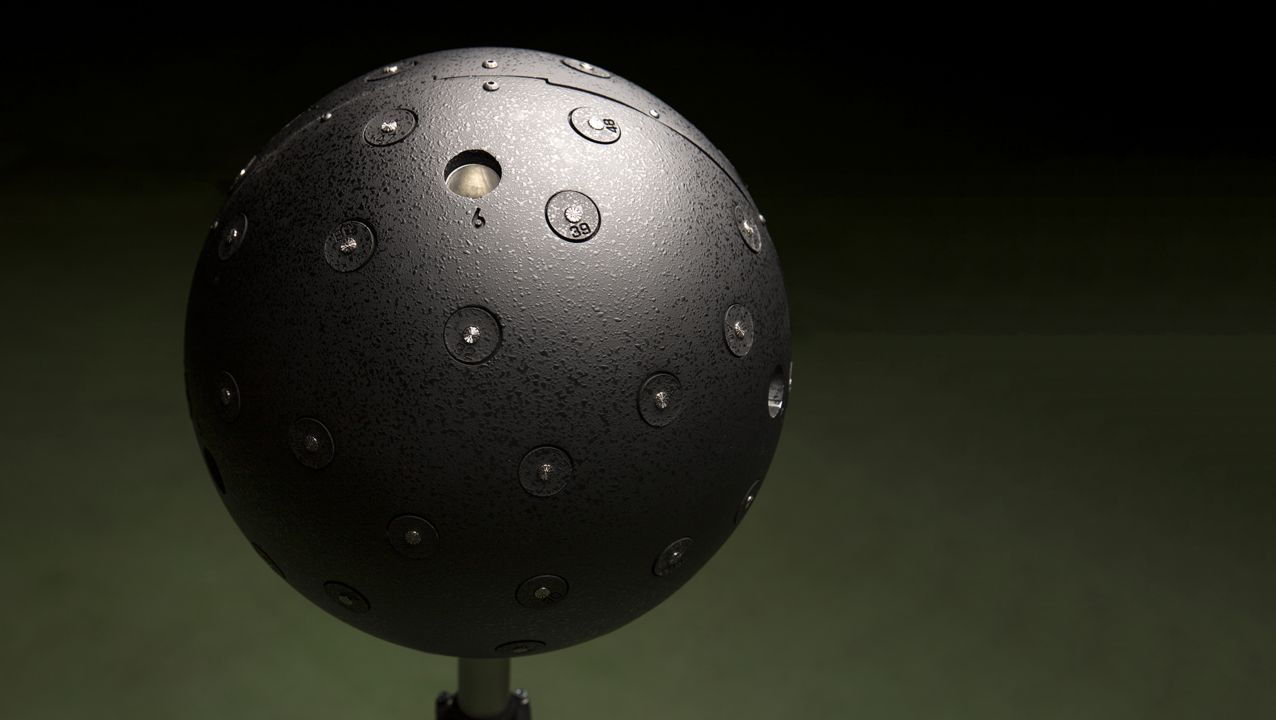
He is sitting in the operator’s room, where a number of computers document the way the test drivers’ drives, watches and positions him/herself on the road. Enormous amounts of information are collected. One of the main advantages of this driving simulator, which is a relatively new kind of test technology, is that it is now possible to include the driver at an early stage in the development of new products.
“It has traditionally been necessary to build everything first – roads, vehicles and safety systems – before tests could be conducted to see if it works in practice. However, it is now possible to do this in parallel,” explains Kristoffer Tagesson.
In other words, the driving simulator makes it possible to test new vehicles in future driving environments and to do it now. Peter Nilsson, another industrial PhD student at Volvo Trucks, is involved in precisely this kind of project.
“The work that is being done on vehicle and infrastructure development is based on a long-term perspective. With this simulator, which is able to visualise basically any road environment, we can optimise these developments together,” he says.
Peter Nilsson’s project is called Safe Corridors and it is investigating ways of finding safe corridors for long vehicle combinations, between 27 and 34 metres.
“By 2020-2030, I am convinced that we shall have these long vehicle combinations on the road, as they are such an environmentally efficient alternative. By then, however, we need to find a way of facilitating driving for the driver, as knowing the exact position of the trailer is a real challenge,” explains Peter Nilsson.